
 EnglishEN
 ItalianoIT
 EspañolES
 PortuguêsPT
 FrançaisFR
 РусскийRU
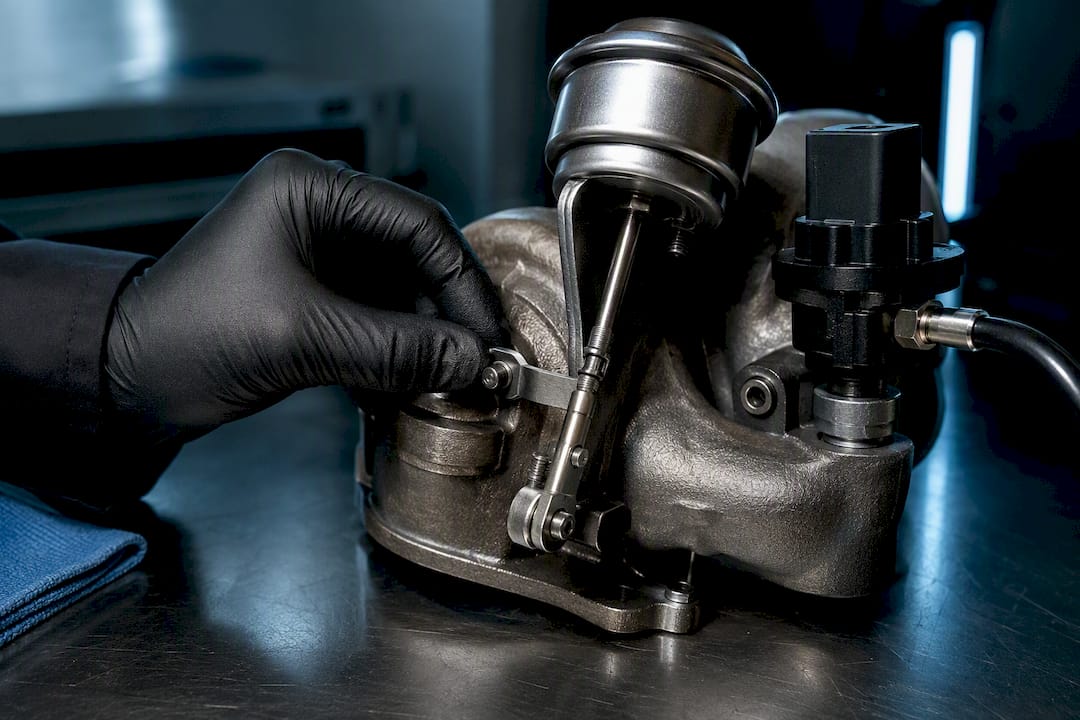
Boost control tuning means calibrating the relationship between the requested operating condition, turbocharger actuator command and measured response. It starts with the hardware and the ECU strategy, not a universal duty-cycle table or PID recipe. This guide focuses on wastegated turbo systems; electronic wastegates and variable-geometry turbos require their own documented control procedures.
Boost control tuning: identify the actuator and pressure reference
Determine whether the system uses a pressure-operated wastegate, an electronic actuator or another arrangement. Confirm the valve plumbing, electrical configuration and sensor calibration against the relevant documentation. A solenoid may divert, interrupt or bleed a pressure signal; it does not always operate as a simple bleed valve.
Verify what the logged pressure represents. Gauge pressure is referenced to ambient pressure; absolute pressure is referenced to vacuum. Mixing those references can make a correct response appear wrong and can corrupt the interpretation of limits.
A zero-percent duty command is not a universal minimum-boost setting. Output inversion, valve routing and ECU conventions affect the result. Establish the documented fail-safe command and actuator operation before progressively applying load.
Measure a baseline without assuming it equals spring pressure
Check leaks, reference hoses, wastegate movement and actuator setup. Measure the response using the manufacturer’s baseline procedure, starting under controlled conditions with appropriate protections active. Do not begin with an unverified full-load pull.
For a pneumatic wastegate, spring rating is only part of the picture. Exhaust pressure, preload, geometry and flow capacity influence the boost curve. A boost rise at higher flow can reflect inadequate bypass capacity even when the controller requests its minimum output.
There is no universal requirement to run a target a fixed number of psi above the spring rating. Select a target within the verified operating limits and controllable range of the system. Do not raise the target merely to create an assumed control margin.
Understand base command and closed-loop correction
Open-loop control applies a command from tables and compensations without correcting the resulting boost error through that loop. Closed-loop control uses feedback to adjust the command. Feedforward and feedback are commonly parts of the same closed-loop strategy, not necessarily a separate “hybrid” mode.
Haltech’s base-duty documentation describes a starting command related to target pressure for its implementation. Other ECUs may work with actuator position, air charge, pressure ratio or torque-related targets. Table axes and units must be verified before editing.
Where a manufacturer specifies an open-loop setup procedure, use repeatable measurements to establish the base table. Choose increments that suit the measured response; no duty-step percentage or RPM spacing is safe for every setup. Avoid abrupt transitions, while retaining genuine behavior changes supported by the calibration strategy.
Diagnose overshoot and oscillation from the whole log
Record the target, measured pressure, base command, correction and final actuator command where available. Also consider RPM, throttle, gear, temperatures, fueling and active torque interventions. A changing target or closing throttle can explain a boost event that would otherwise be blamed on PID.
| Observation | Possible checks |
|---|---|
| Transient overshoot | Spool strategy, feedback activation, command delay, integral state and actuator authority. |
| Repeated oscillation | Gains, filtering, sensor noise, hardware response and interacting control loops. |
| Persistent shortfall | Leaks, target feasibility, exhaust or intake restriction, actuator travel and command saturation. |
| Boost rises at minimum command | Confirm output convention, then investigate plumbing and wastegate bypass capacity. |
These are diagnostic possibilities, not one-to-one fault rules. Gain scaling, controller interval and derivative filtering vary by ECU. A derivative increase is not a universal cure for spool overshoot, and reducing proportional gain cannot fix a stuck actuator.
Keep component limits distinct from control targets
The operating target and protection threshold have different purposes. Choose limits using the engine, turbocharger, fuel system, sensor range and manufacturer guidance. A fixed overboost offset or delay from another vehicle is not a substitute for that assessment.
Ambient pressure and intake temperature affect compressor operation. Holding the same gauge boost at a different altitude does not mean the turbo is working at the same pressure ratio or speed. A pressure-control loop alone does not guarantee acceptable turbo speed, exhaust temperature or knock margin.
Fuel composition and transmission torque requests can also alter what the engine can support. Confirm the applicable compensations and retain the ECU’s protective responses rather than increasing limits to silence an intervention.
Build a validation record that explains the result
Compare revisions under matched conditions and record deviations such as gear, starting temperature or fuel blend. Evaluate steady load and transients, including shifts and throttle changes where relevant. Increase the tested operating range progressively.
Investigate isolated spikes instead of automatically rejecting them as bad data. Check sensor range, sampling and repeatability while preserving the original capture. A smooth graph may hide a short event if the logging rate or export averaging is inadequate.
Close the job only against documented platform-specific acceptance criteria. Keep the starting calibration and revision history, and return to a known reference if a change makes behavior worse.
Häufig gestellte Fragen
Does zero WGDC always mean spring boost?
No. Output inversion, solenoid routing, actuator type and ECU conventions determine the response. Use the documented baseline method.
How much boost should I run above wastegate spring pressure?
There is no universal offset. The target must be achievable within the verified control range and component limits.
Can PID tuning cure boost creep?
Not when the cause is insufficient bypass capacity or a hardware fault. First confirm command direction and minimum-boost operation, then investigate the hardware.
Are boost PID values transferable between ECUs?
No. Units, sample intervals, filtering and actuator behavior vary, so use the exact controller documentation.
References and further reading
- HP Academy: technical training: open-loop boost — Training material; apply procedures only to the described system.
- ECMTuning: boost control setup — Controller-specific documentation.
- MOTIV: Turbo Boost Control Guide — ReFlex+ guidance; example gains and offsets do not transfer to other controllers.
- MAPerformance: turbo upgrade considerations — Hardware background, not a source of universal control settings.